8
industry verticals
Diverse
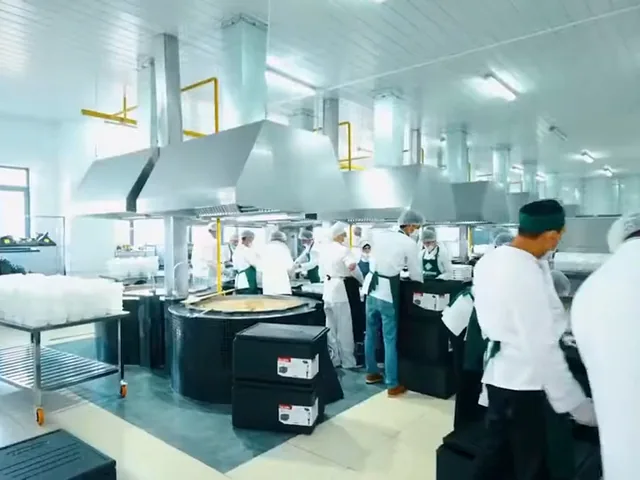
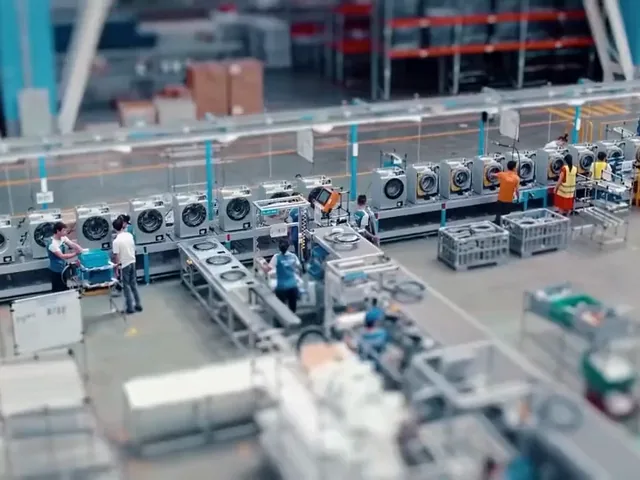
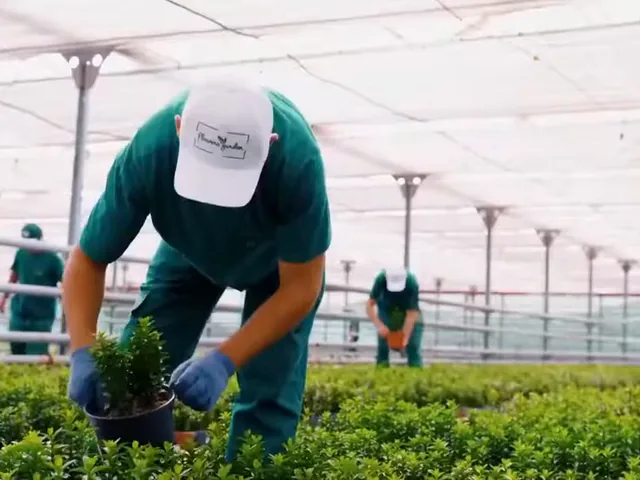
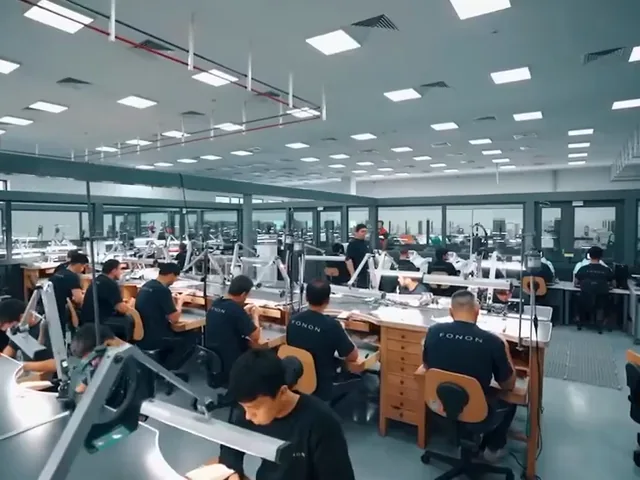
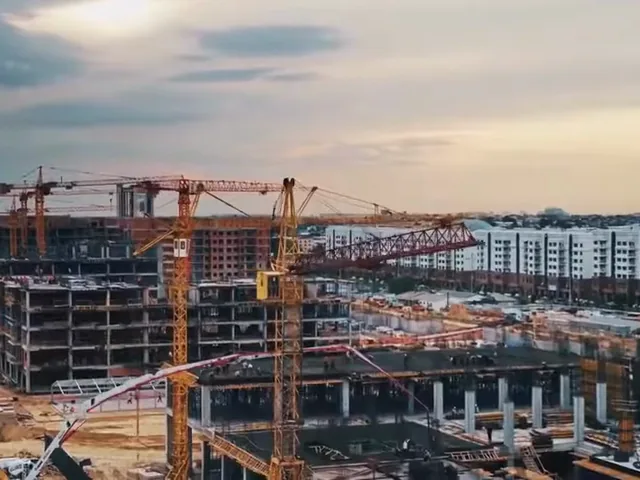
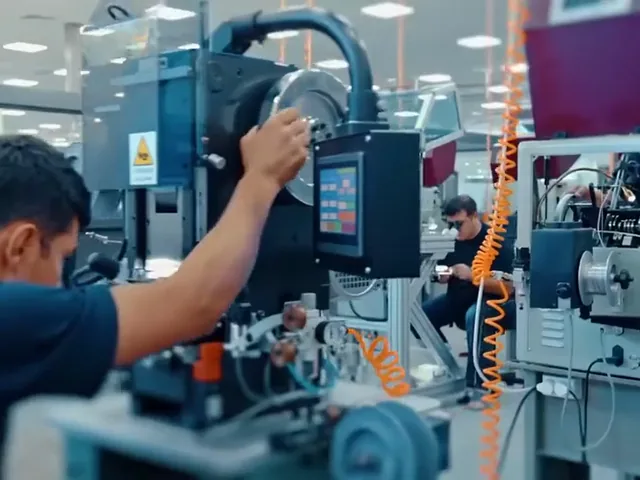
Factories, warehouses, kitchens, hotels, construction and mining sites — real shifts with real variability, lighting changes and the long tail of edge cases a lab never produces.
Human-in-the-loop data collection · Physical AI & robotics
Humaid collects real-world, egocentric demonstration data for robotics — across manufacturing, warehouse, hospitality, and food service environments. Calibrated multi-sensor capture, trained operators, annotation, QC, and pipeline delivery.
Exclusive pilot program
Humaid launches its groundbreaking exclusive pilot program with one of the largest companies in Central Asia, AKFA Group — live capture across factories, logistics, construction, hospitality and retail sites.
What Humaid offers
Every session is multimodal by default. All signals are timestamped on one clock and delivered in a single MCAP container — ready for policy training without a stitching step.
How it works
One vertically integrated pipeline. We do not crowdsource annotations or repurpose internet video — every dataset is collected on-site with calibrated equipment, trained operators and human review at every gate.
We define the task list, environments, sensor configuration, annotation schema and target volume with your team — then calibrate a rig for it. Onboarding a new dataset is configuration, not a new codebase.
Trained, consenting operators wear calibrated multi-sensor rigs during their actual shifts — factories, kitchens, warehouses, hotels. Twenty rigs record today and fifty more are being deployed; sessions are remotely monitored, health-checked and auto-cut hourly.
A vision model proposes work segments; annotators review every proposal on a millisecond-precision timeline. Nothing ships without a human gate, and random clips are re-audited for quality.
Neural depth, 21-keypoint 3D hands with wrist-camera calibration, full-body mesh, and temporal action labels — every stream aligned on one clock, with provenance flags so you can filter what you trust.
Automated validators reconcile every chunk, faces are blurred, manifests are checksummed. Datasets land in your bucket or on Hugging Face as MCAP — or converted to HDF5, RLDS and LeRobot.
Data source verticals
Access to large industrial environments where we run live pilots and capture rare edge cases at scale — people doing their actual jobs, not actors in a lab.
Assembly, machine tending and inspection on live production lines for cement, steel, glass and other building materials.
Picking, sorting, packing and pallet handling in distribution centres and cross-border logistics hubs.
Material handling, tool use and assembly work on residential, commercial and industrial sites, under real safety constraints.
Equipment operation, maintenance and material handling at extraction sites — heavy, safety-critical work far from any lab.
Housekeeping, room service and front-of-house routines at large hotel and resort venues.
Commercial kitchens and processing plants — prep, plating, packaging and cleaning at institutional scale.
Shelf stocking, checkout and back-of-store handling across multi-format stores, with real customer flow.
Pharmaceutical production and clinical support routines — sterile handling, packaging and logistics in regulated environments.
Why us
We deliver diverse, hard-to-access real-world datasets through exclusive pipelines and partnerships, tailored to your exact use case — so you get model-ready data that fits your roadmap and scales to production.
industry verticals
Factories, warehouses, kitchens, hotels, construction and mining sites — real shifts with real variability, lighting changes and the long tail of edge cases a lab never produces.
rigs in the field · 3 cameras each
+50 deploying soonA fleet of remotely monitored capture rigs — 20 recording today, 50 more being deployed — with hourly auto-cut sessions and a durable, config-driven pipeline that turns terabytes per day into reviewed, labeled clips.
channels on one clock
Stereo RGB-D at 1920×1200, three IMUs at ~200 Hz, hand and body pose, action labels — every signal in one MCAP with factory calibration and 0.00 ms depth-to-frame pairing.
Open data
Inspect real sessions in the Data Explorer and download an open dataset — the same MCAP files we deliver to customers.
5,392 clips across 12 task categories, recorded on the job. Every clip is a self-contained MCAP with ego, wrist, depth, IMU, hand pose and action labels.
Browse sessions, scrub synchronized camera views, depth and pose, and filter by task, environment and duration before you request a dataset.
Insights
12 min read
How to architect a robotics data collection pipeline that scales from prototype to production. Sensor capture, annotation, QC, and delivery for robot training.
Read article11 min read
How to collect teleoperation data for robot learning. Interfaces, sensor streams, action labeling, and scaling strategies for behavior cloning and diffusion policies.
Read article10 min read
Why simulation cannot replace real-world data for robot training. Contact dynamics, material properties, and edge cases that only exist in physical environments.
Read article